Lightweight Arms with Impressive Capabilities
The RealMan RM65 series combines a lightweight design with a respectable payload capacity. The Standard version weighs just 7.2 kg, while the Six-Axis Force version is only slightly heavier at 7.3 kg. Despite their low weight, both versions can handle payloads of up to 5 kg, making them attractive options for applications where robot size and weight matter.
The cobots feature six degrees of freedom with a humanoid-inspired arm configuration, allowing them to perform a variety of movements and manipulation tasks. They also offer a working radius of 610–627 mm, depending on the version, and a positioning repeatability of ±0.05 mm.
Another practical feature is their compact construction, with the controller integrated into the base of the arm. Combined with flexible mounting options, this makes the RM65 series suitable for integration into workstations, service equipment, and more complex robotic systems.
Where Can These Cobots Be Used
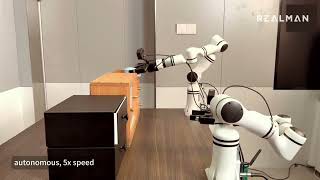
The RM65 cobots are designed for more than just conventional factory automation. RealMan promotes these robotic arms for applications across retail, food and beverage, healthcare-related services, education, and other service environments.
With suitable end-effectors and programming, the RM65 arms can perform tasks such as picking and placing objects, handling products, sorting items, and supporting light assembly or inspection operations. In retail and food service, they can also be integrated into automated preparation or dispensing systems, depending on the equipment and task requirements.
Their lightweight construction and available development tools also make them appealing for universities, research laboratories, and robotic system developers. Researchers can use these arms to explore robot manipulation, motion planning, and human-robot interaction.
The key advantage is flexibility: rather than being limited to one application, the RM65 series provides a compact robotic arm platform that can be adapted to different tasks through appropriate software, tooling, and system integration.
Force Sensing and Simplified Programming
One of the main choices within the RM65 series is whether to select the Standard version or the Six-Axis Force version. Both offer the same payload capacity and positioning repeatability, but the Six-Axis Force version adds an integrated sensor that measures forces and torques at the robot's end.
This allows developers to implement force-aware behaviours for tasks involving physical contact, such as controlled pressing, contact-based manipulation, or force-controlled research experiments. The sensor has a rated measurement range of 200 N and 7 N·m, with a specified accuracy of ±0.5% of full scale.
RealMan also provides multiple programming options, including drag teaching, teach pendant control, and software development interfaces. ROS and ROS 2 resources further support integration into research and customised robotic systems.
The arms also support configurable collision protection. However, collaborative operation still requires proper configuration, application-specific risk assessment, and suitable safety measures.
Comparing the RM65 Models
RM65 Standard (RM65-B)
Payload: 5 kg | Reach: 610 mm | Weight: 7.2 kg | Repeatability: ±0.05 mm
Best suited for: General-purpose handling, pick-and-place, light assembly, education, and applications that do not require integrated six-axis force feedback.
RM65 Six-Axis Force (integrated 6FB configuration)
Payload: 5 kg | Reach: 627 mm | Weight: 7.3 kg | Repeatability: ±0.05 mm
Best suited for: Force-sensitive manipulation, controlled-contact tasks, robotic research, and applications requiring integrated force and torque measurements.
RM65 Series vs Other RealMan Cobot Series
RealMan offers several robotic arm families designed around different priorities, including weight, reach, configuration, and cost.
The RM65 and RM75 are closely related. Both belong to RealMan's ultra-lightweight, humanoid-configuration RM family and offer 5 kg payloads. The main difference is that the RM65 has six degrees of freedom, while the RM75 has seven, providing an additional joint for more flexible positioning. The RM75 is also slightly heavier, weighing 7.8–7.9 kg compared with the RM65's 7.2–7.3 kg.
The ECO series, particularly the ECO65, takes a different approach. The ECO65 has the same 5 kg payload and comparable reach and repeatability to the RM65, but uses a conventional collaborative-arm configuration and mechanical brakes across all six joints. RealMan also positions the ECO family as an economical option.
For applications requiring greater reach, the RML63 offers 900–917 mm of working radius, compared with the RM65's 610–627 mm. However, this comes with a lower payload capacity of 3 kg and a heavier arm weighing 10–10.1 kg.
Meanwhile, the RX75 is a seven-axis humanoid-oriented arm with a different wrist configuration, integrated six-axis force sensing, and an available vision version with an Intel RealSense D405 camera. It is especially relevant for humanoid and dual-arm robotic systems.
Overall, the RM65 occupies a practical middle ground in RealMan's lineup: it is particularly lightweight, retains a 5 kg payload, and offers optional force sensing without the extra joint, weight, or reach of some other models.
 Research
 Industrial
 Consumer
 Social
 Service
 Assistive
 Medical & Healthcare
 Emergency Response
 Building & Construction
 Other Infrastructure
 Transport
 Arts & Entertainment
 Agriculture & Forestry
 Law & Order / Security
 Other

 RealMan Robotics


 Multi/General-Purpose Robots
 View All
 Linkedin
 in Sydney, Australia.
Share